Projects
BDX-R
ISAACLAB // RL // CAD // 3D PRINTING // PYTHON
A custom bipedal robot inspired by Disney's BD-X Robots. I reverse engineered the BD-X to build my own, then trained and deployed a walking RL policy from IsaacLab to real hardware.
View ProjectStompy
REINFORCEMENT LEARNING // ROBSTRIDE // 3D PRINTING // CAD
A fully 3D-printed bipedal robot built and taught to walk in 7 days for a Bambu Lab challenge, trained with RL and deployed to the real hardware.
View ProjectBooster T1 RL Locomotion
ISAACLAB // MUJOCO // PYTHON // PYTORCH
Migrating Booster Robotics' deprecated Isaac Gym pipeline to IsaacLab, and building custom RL walking policies for the Booster T1 humanoid.
View ProjectBooster T1, Kicking
ISAACLAB // REINFORCEMENT LEARNING // SIM2REAL
Training a Booster T1 humanoid to kick a ball, from IsaacLab simulation to a real RoboCup field.
View ProjectDancing with Booster T1
BEYONDMIMIC // ISAACLAB // MOTION RETARGETING
Implementing BeyondMimic on the Booster T1 to retarget motion capture dance sequences into a real RL policy.
View Project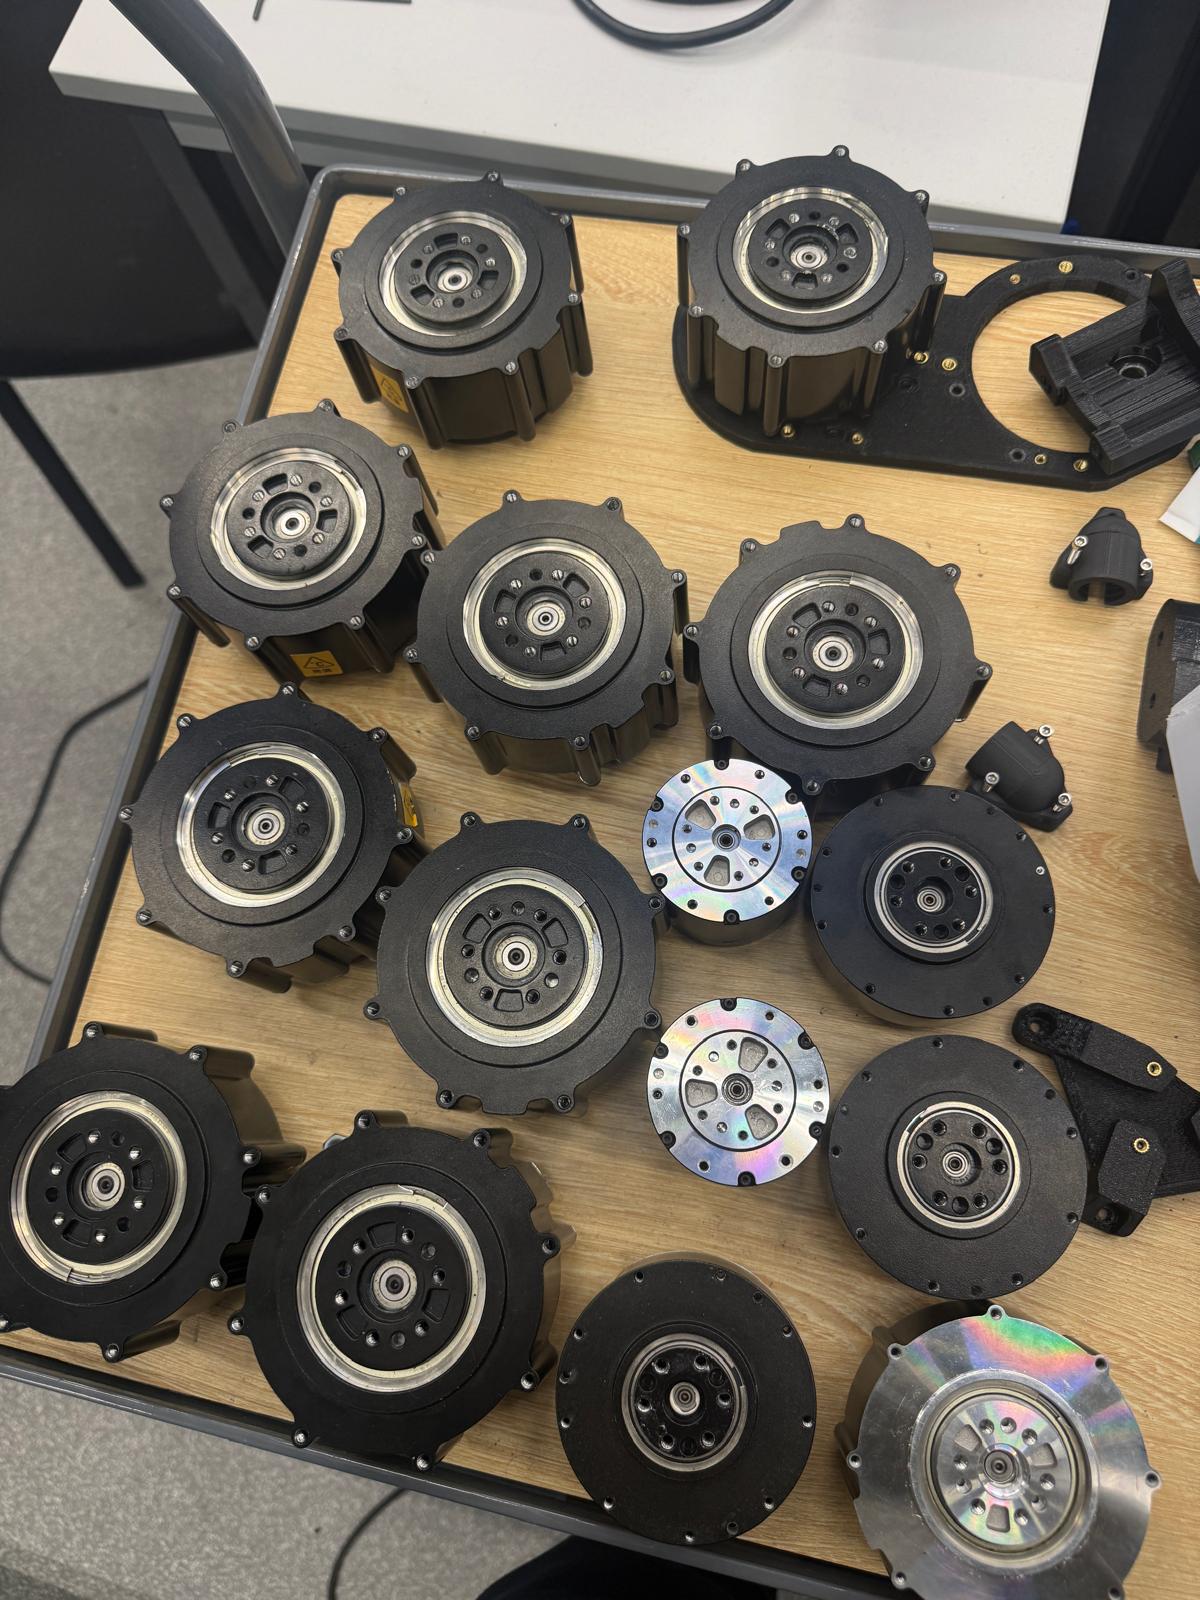
Robstride Actuators Control
PYTHON // CAN BUS // MIT CONTROL
Open-source Python driver for controlling Robstride motors over CAN bus using MIT Control Mode, now used by thousands of builders.
View Project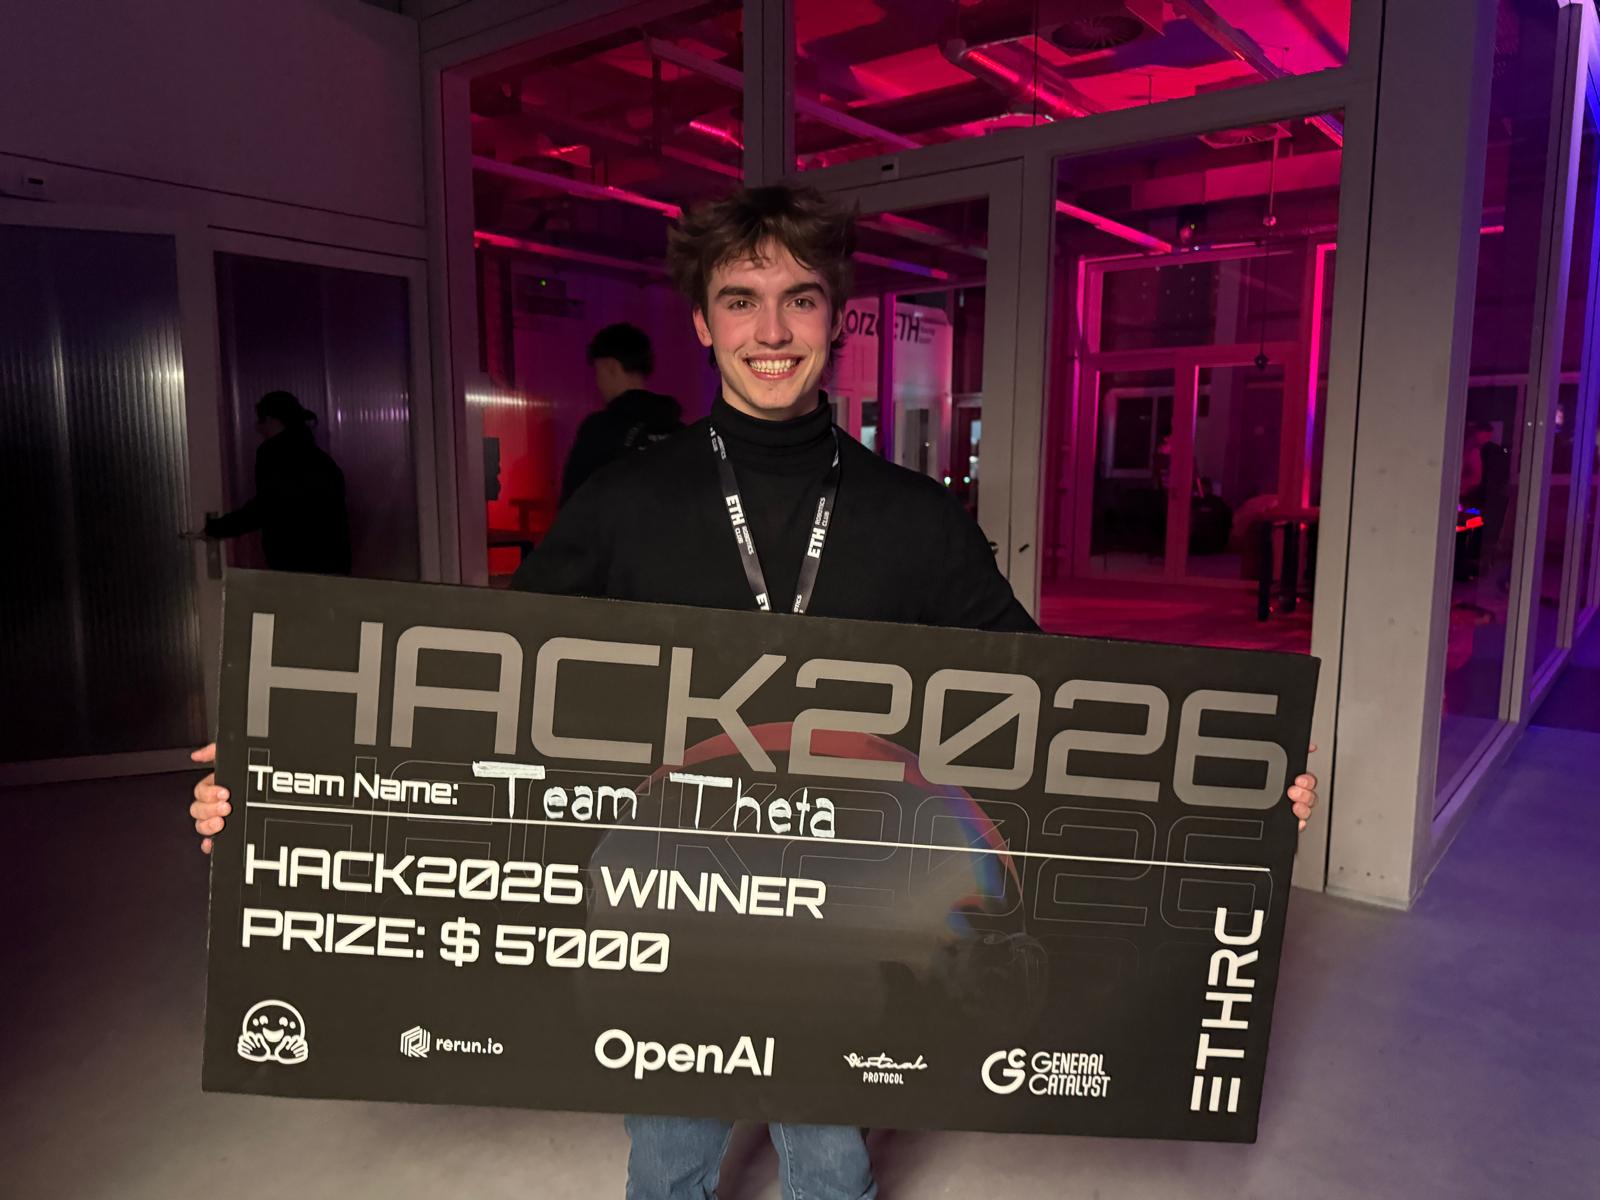
🏆 HACK2026, 1st Place
LEROBOT // NVIDIA GR00T // IMITATION LEARNING // GPS NAV
Won ETH Robotics Club's HACK2026 against 500+ applicants. Built a humanoid robot that autonomously navigates outdoors and handles objects, targeting Europe's labour shortage.
View ProjectComing Soon: Bipedal Robotic Character Design Internship
CHARACTER DESIGN // BIPEDAL ROBOTICS
Currently interning on bipedal robotic character design. Full writeup once I'm able to share details.
Coming Soon